Multi-Robot Planning and Control from CCTV Camera Networks
In collaboration with
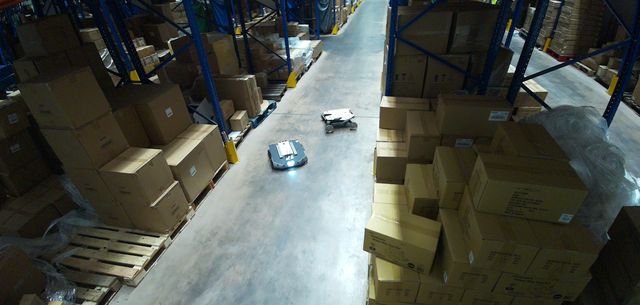
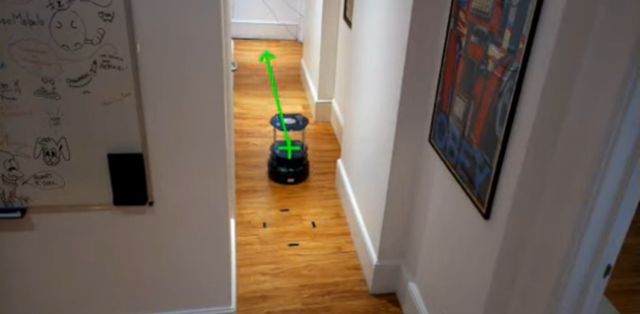
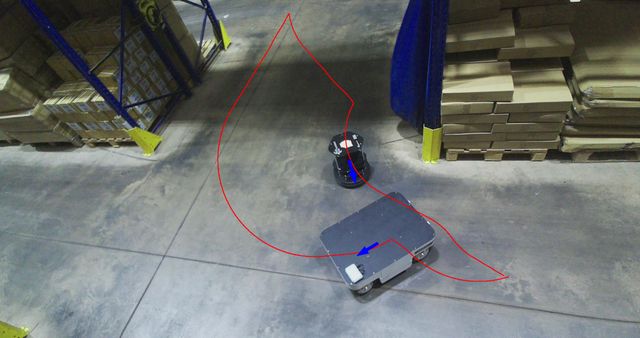
A network of CCTV cameras and an edge server coordinates four different robots in a working warehouse, with perception, planning, and control handled offboard. The system uses an uncalibrated camera network to navigate narrow aisles, avoid collisions, and manage shared routes without task-specific sensors on the robots.