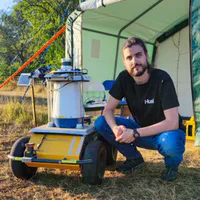
Daniele De Martini
Daniele De Martini is Associate Professor in Mobile Robotics at the Oxford Robotics Institute and the Oxford e-Research Centre, University of Oxford, and Tutorial Fellow in Engineering Science at Keble College. He co-leads the Mobile Robotics Group alongside Professor Paul Newman. His research combines robotics and artificial intelligence to design autonomous systems capable of perception, mapping, localisation, and adaptive decision-making.
By exploiting multiple sensing modalities—from vision to lidar to radar—his group explores how robots can reliably navigate and interpret the world, even in challenging or extreme conditions. Daniele has deployed robots in environments ranging from urban Oxford to the Scottish Highlands. Another key aspect of his work examines robotics–infrastructure interaction, enabling dynamic sharing of sensing and computing resources between robots and smart environments to support safe and scalable autonomy.
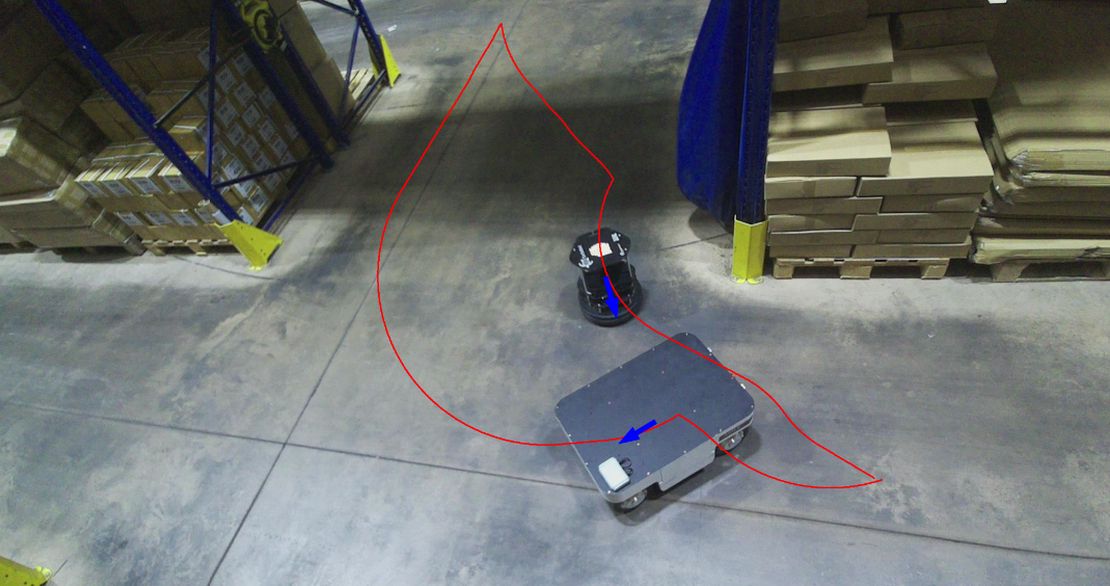
Multi-Robot Planning and Control from CCTV Camera Networks
A network of CCTV cameras and an edge server coordinates four different robots in a working warehouse, with perception, planning, and control handled offboard. The system uses an uncalibrated camera network to navigate narrow aisles, avoid collisions, and manage shared routes without task-specific sensors on the robots.
Read More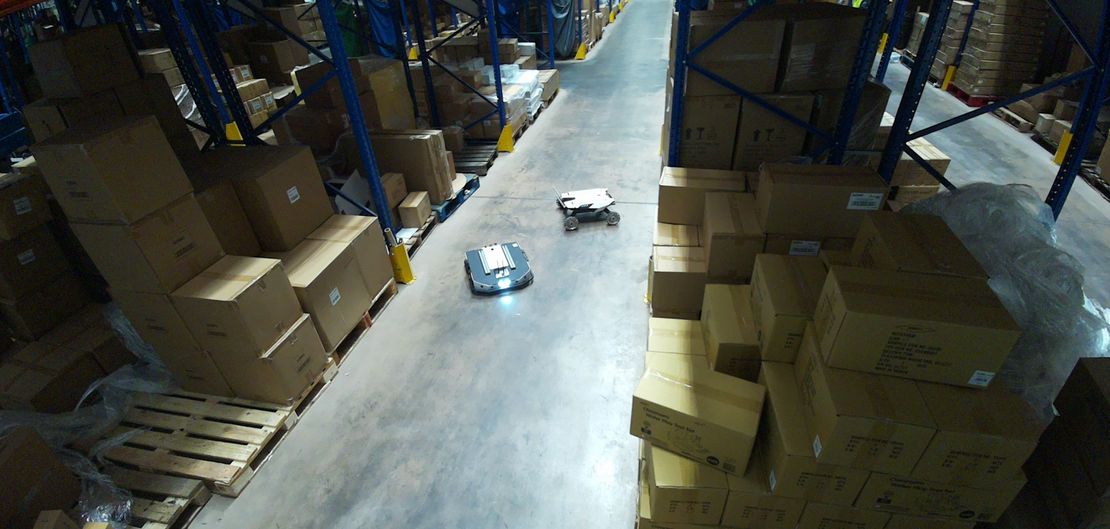
Scaling Robotic Infrastructure: A Case Study in Orchestration
This warehouse study investigates how configuration-driven orchestration can simplify the deployment of robots, cameras, and computing infrastructure. Working with Omniscient Innovations and Gompels Healthcare, we compared a shared configuration model with manual setup, finding shorter deployment times and fewer configuration errors as systems grew.
Read More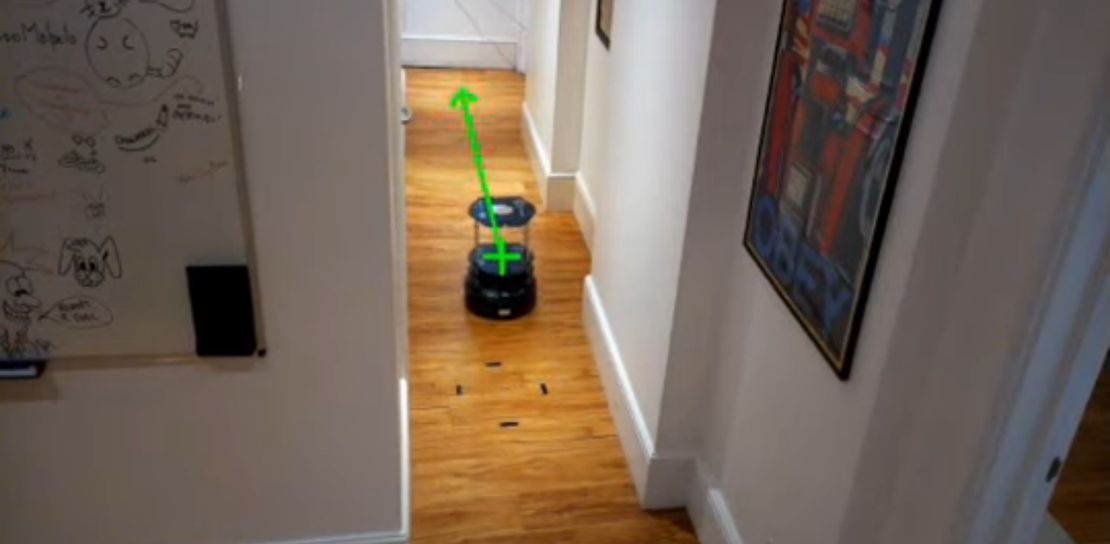
Building-Scale Robot Navigation via a Relay of External Cameras
A network of external cameras guides a mobile robot across an office floor without onboard sensing, SLAM, or camera calibration. The system learns connections between camera views by observing people, then hands control between cameras so the robot can navigate through multiple rooms and corridors.
Read More