
Kyuhwan Yeon
Kyuhwan Yeon is a DPhil student in the Mobile Robotics Group at the Oxford Robotics Institute, supervised by Prof. Daniele De Martini.
Before joining ORI, he worked at 42dot (Hyundai Motor Company) on learning-based decision making, motion prediction, planning, and control for autonomous driving. He earned his M.S. in the Automotive Control & Electronics Lab and his B.S. from Hanyang University.
His research interests focus on scalable robot learning algorithms for long-term autonomy.
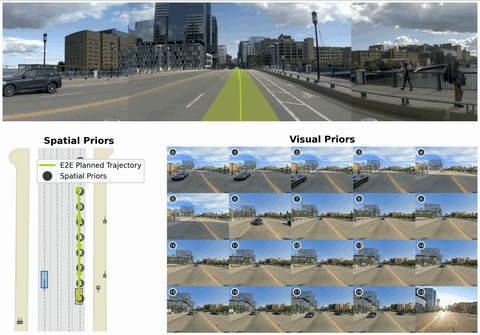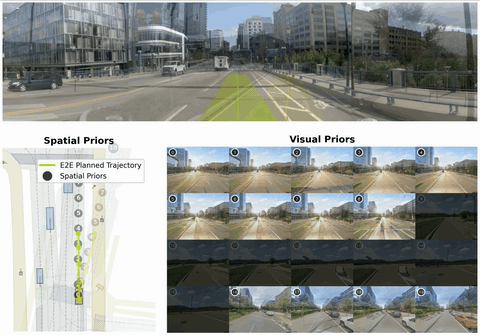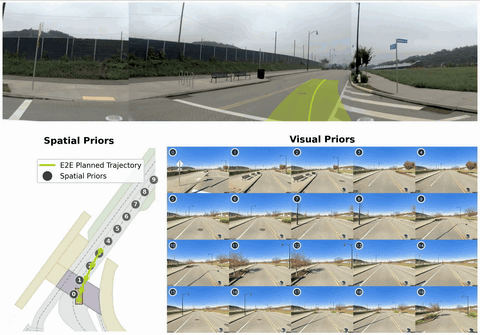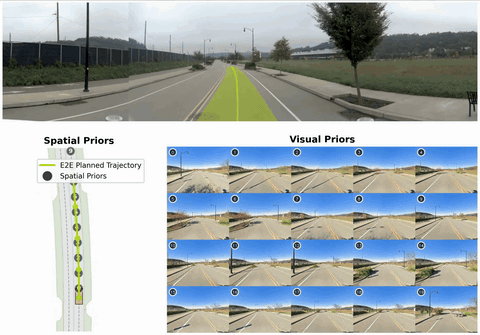
PriorEye: Geospatial Visual Priors for End-to-End Autonomous Driving
PriorEye gives end-to-end driving models visual context from street-level images captured along their planned route at other times. A dual-memory module combines these location-specific priors with a learned fallback, improving driving performance and resilience when onboard sensors or retrieved images are unreliable.
Read More